Technology that reads land and remakes it: a 3D scan of the ground, a design drawn on it, orders a crew can follow, and the care that keeps it alive. The end goal is the health of the place and everything that lives there.
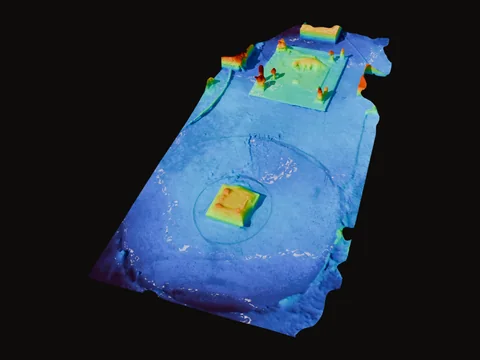
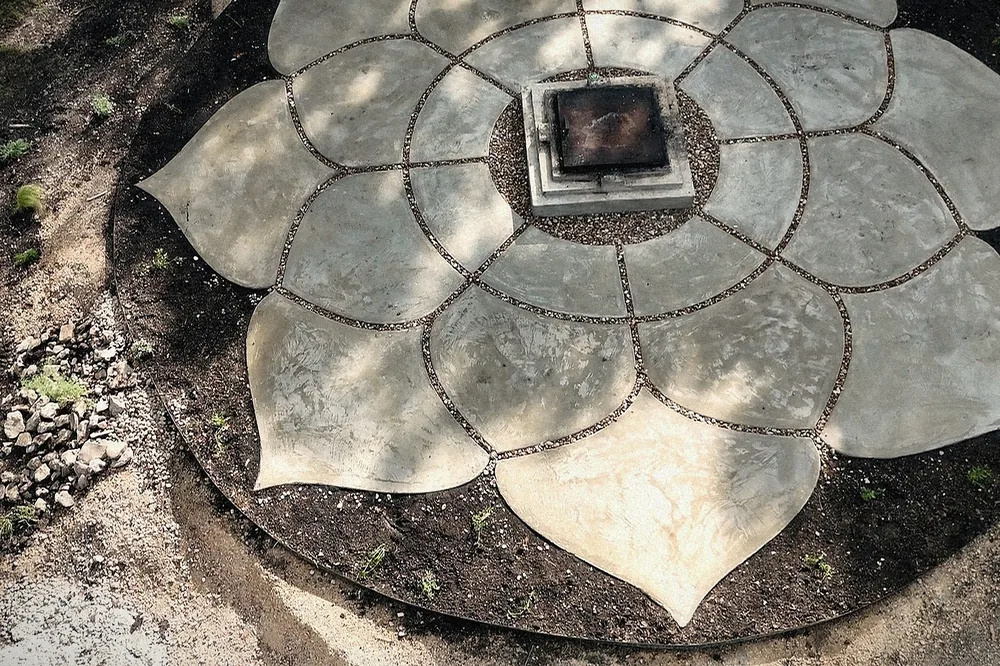
Fig. 01 · The Lotus, beforeHill Country · May 2026Phone LiDAR · one passLowHigh
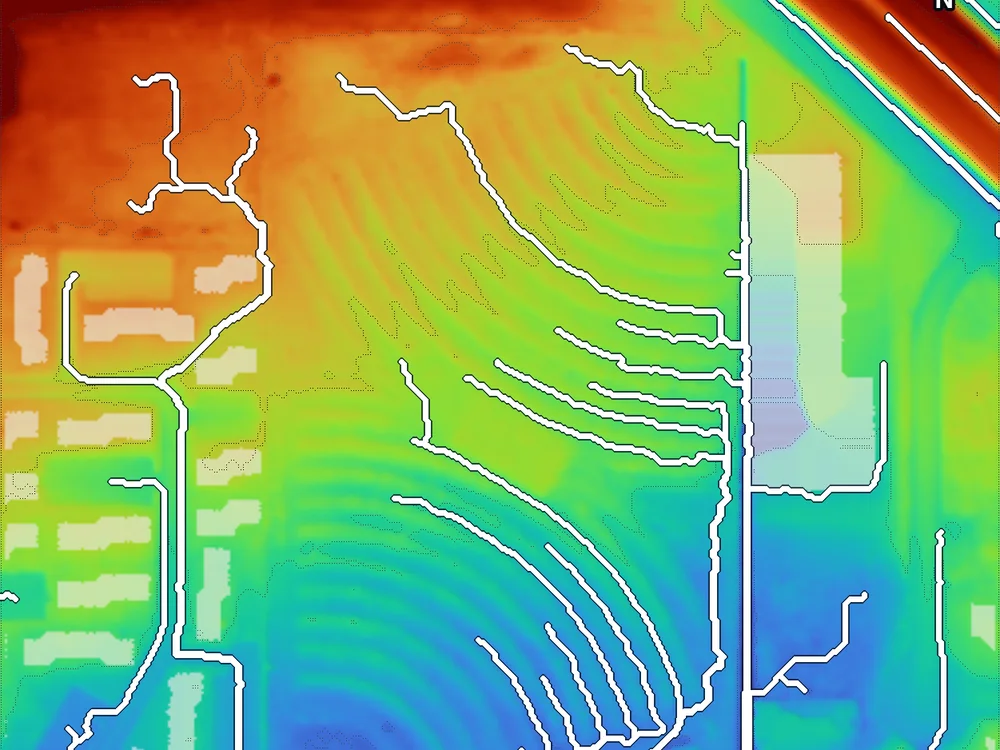
01ScanOne walk with a phone’s LiDAR, or the public lidar flown over the county: every slope, tree and wall to the inch, and the path the water takes.The ground, read
02TerraformThe design drawn on the real ground: grades, stone, water and native plants, each placed, counted and named.Set out on the ground
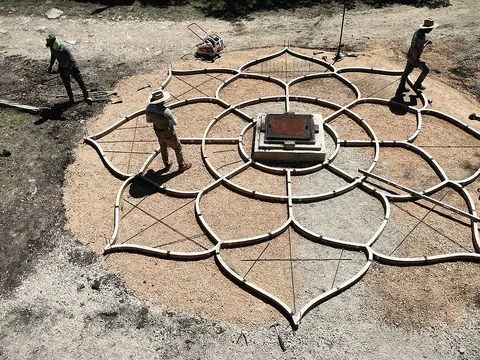
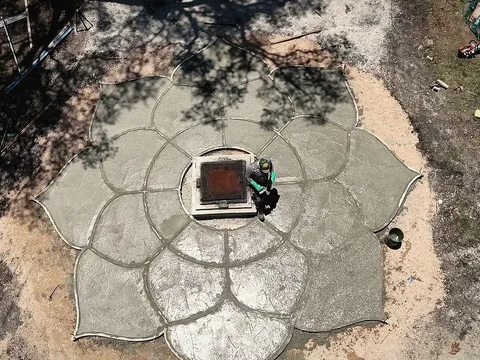
03BuildWork orders a crew can follow in English and Spanish: where each stone goes, how much, and in what order.Poured in place
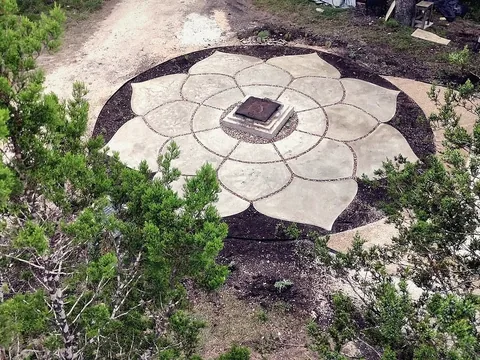
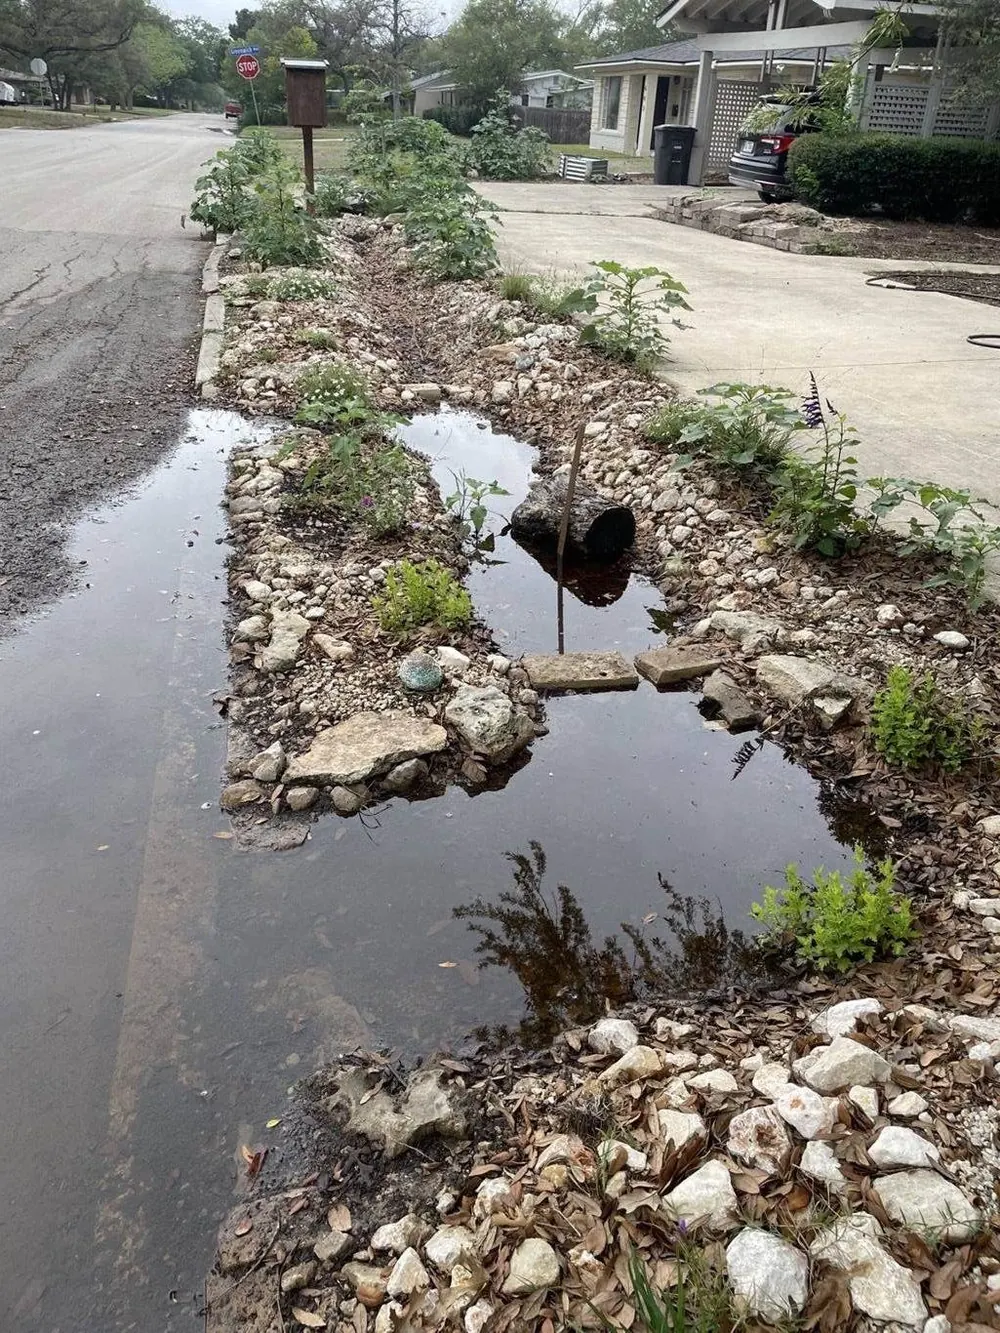
04Grow healthCare timed to the ground’s own year: freeze nights, 100° days and rain, until the soil is alive again.Finished, in the oaks
Shown here on one place, start to finish: the Lotus →
The app · free on iPhone
Noon: Wake the Land
Walk your yard once with an iPhone Pro. Noon keeps it to the inch with the phone’s LiDAR, then shows what is under it: the soil, the rock, the water table, the roots.